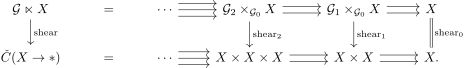Definition 6.31. (Shear maps)
Let \(\Gg \ltimes X\) be an action of a groupoid object \(\Gg\) on an object \(X\) in \(T\). We define the shear map of \(\Gg \ltimes X\) as the map
where \(a\colon \Gg_1 \times_{\Gg_0} X \to X\) is the action map and \(\pr_X\) is the projection onto \(X\).
More generally, we define the higher shear maps as follows. The atlas \(X\to X\quot\Gg\) is an effective epimorphism, and the equivalence of Lemma 2.33 identifies the action groupoid \(\Gg\ltimes X\) with its Čech nerve \(\check{C}(X\to X\quot\Gg)\). Consider now the commutative square

Regarding this as a morphism from \(X \twoheadrightarrow X\quot\Gg\) to \(X \to *\) in \(\Ar(T)\) and passing to Čech nerves, we obtain a morphism of groupoid objects
Under the identifications of Remark 6.28, this may be displayed as follows: